Arduino Bluetooth Robot: Parts and Design Overview
An Arduino Uno, HC-05 Bluetooth module and dual-motor driver can form the basis of a phone-controlled rover. This article outlines the concept and does not present a tested circuit.
🛠️ Bill of Materials
🔌 Circuit Design & Connections
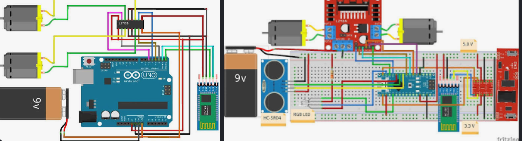
The motor driver controls the two motors while the Bluetooth module carries commands to the Arduino. Connections and voltage requirements depend on the exact module versions. The earlier pin list has not been validated as a complete circuit.
Firmware design checks
The earlier pasted code block was malformed and had no verified fail-safe behaviour. It has been withdrawn. A working sketch needs a validated pin map, a stopped initial state, command handling and a safe response to lost control.
Phone control considerations
Phone control is a separate software task. A suitable interface must send commands that match the verified firmware and provide an obvious stop control. The earlier app and pairing instructions were generic and untested for this specific build. Confirm compatibility with the exact Bluetooth module and phone before describing the project as complete.